Community project
ESP-NOW Quadcopter Controller
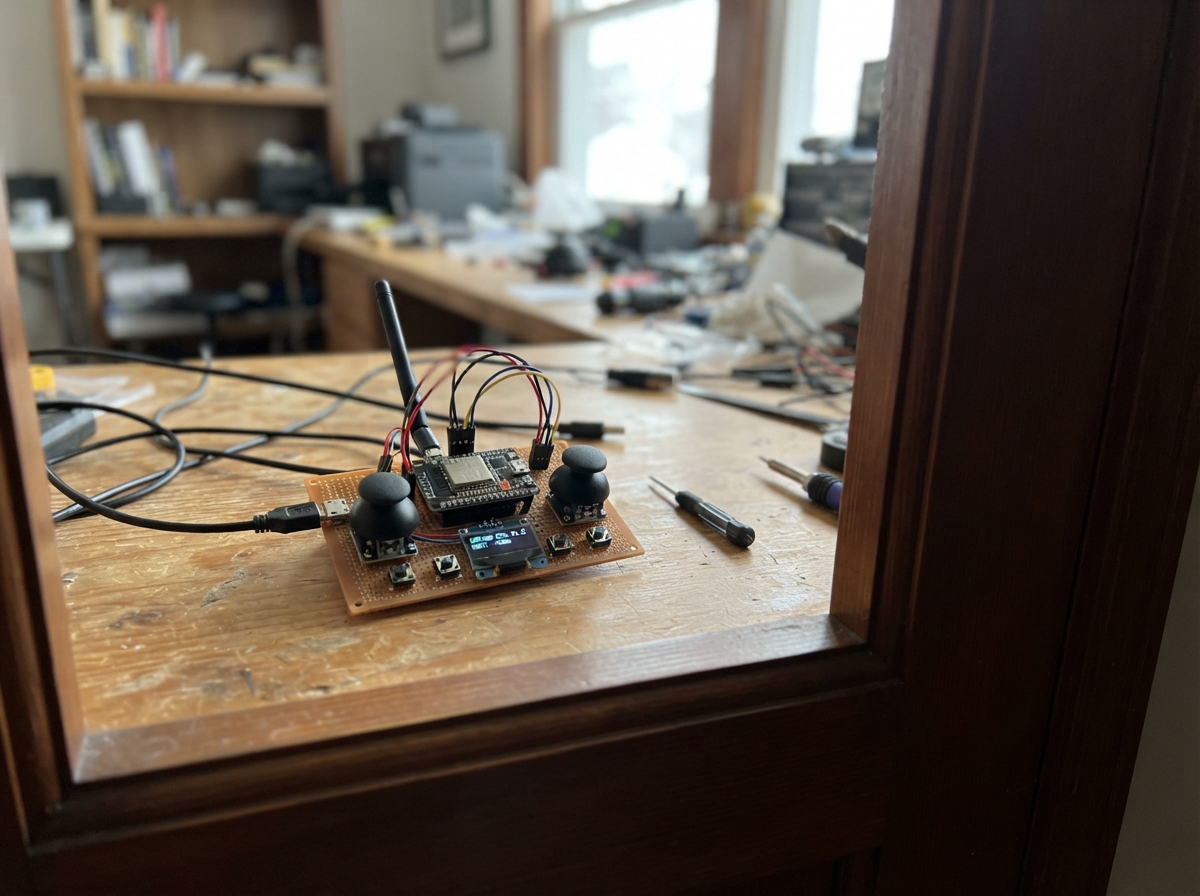
This guide builds a wireless quadcopter controller using ESP32 and the ESP-NOW protocol for low-latency communication. The controller features dual analog joysticks for throttle and directional control, with a compact form factor suitable for hand-held operation.
The project includes a complete wiring diagram, parts list, and Arduino firmware with joystick calibration routines. Builders will learn how to configure ESP32 devices for peer-to-peer communication, map analog inputs to control signals, and optimize latency for responsive flight control.
Wiring diagram
Remix this project
Make it yours in one click
Open a full copy of this project in your own Schematik workspace, diagram, code, parts, and assembly steps included. Swap the sensor, add features, or redesign the whole thing with AI. The author's original stays untouched.



