Community project
Lobster Companion Pet Bot
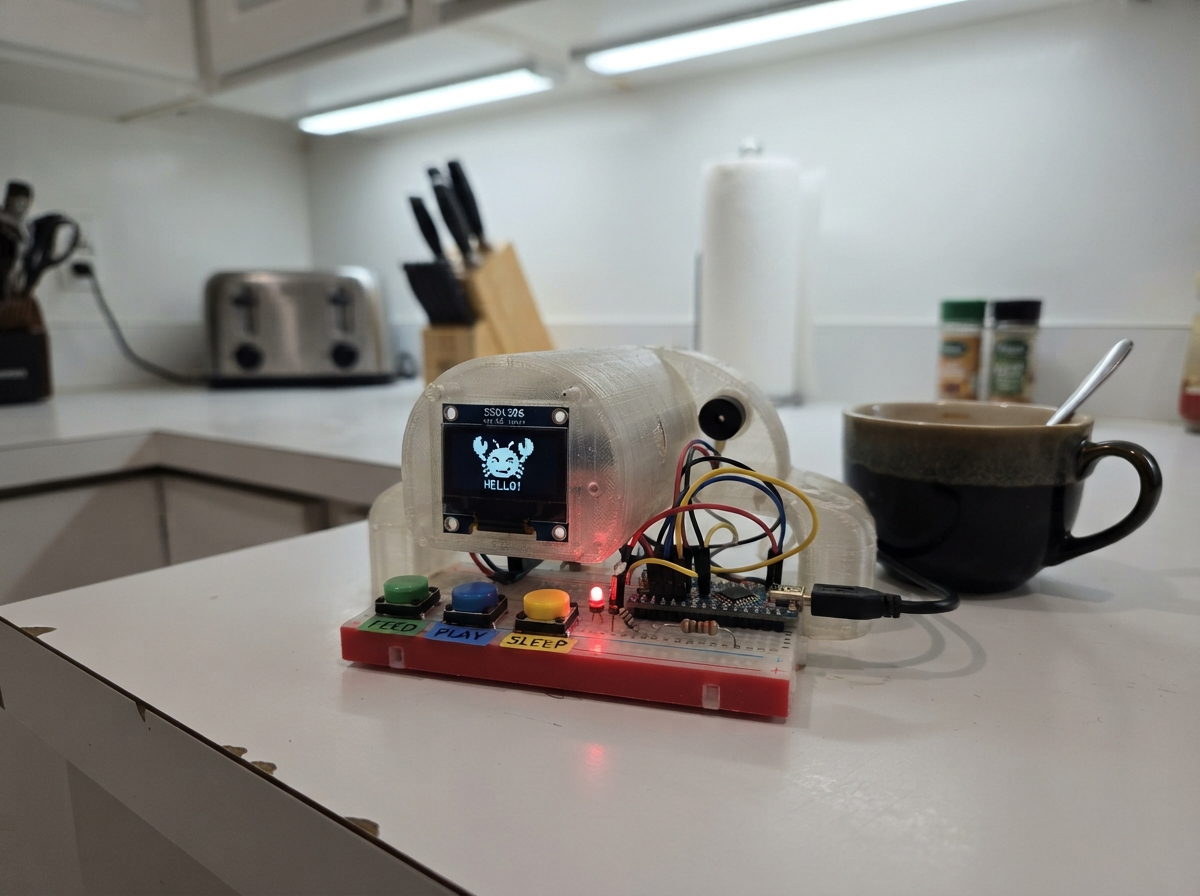
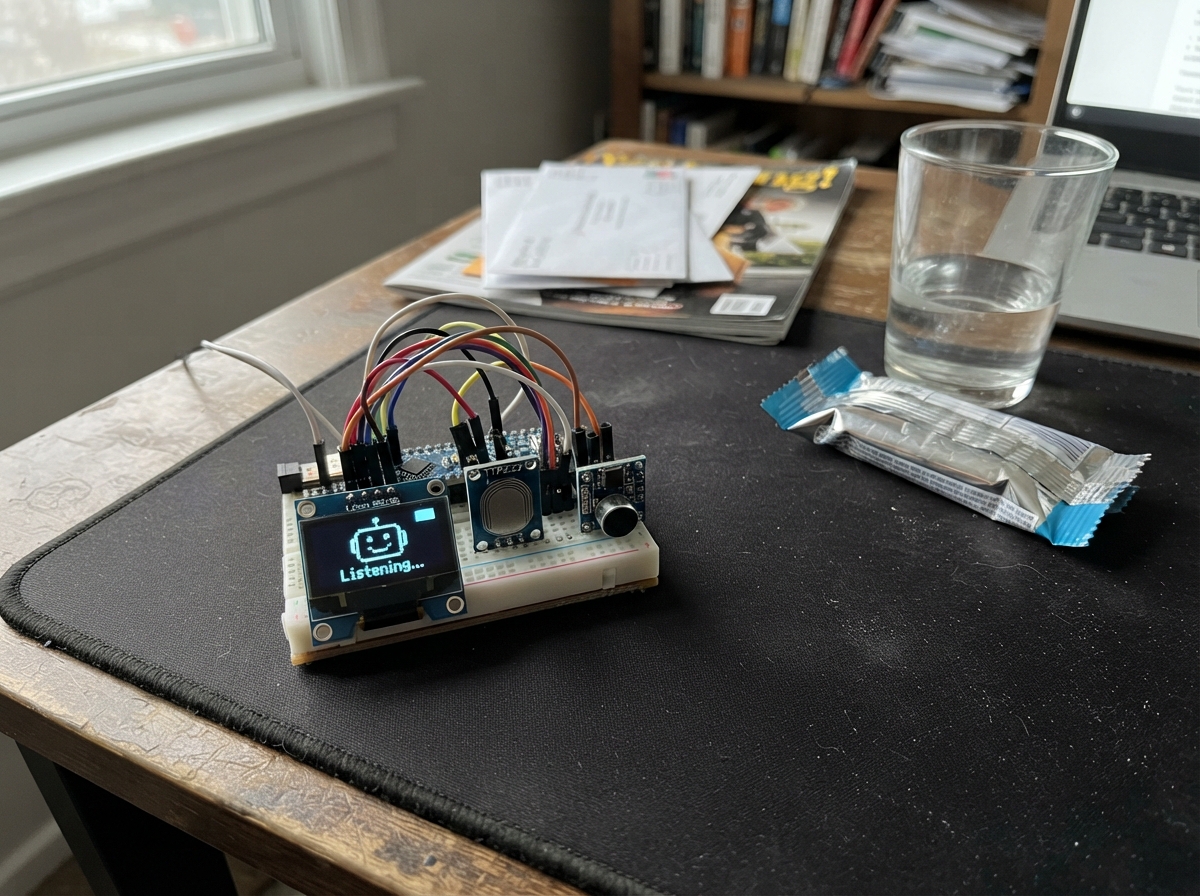
Build a digital companion pet that lives on an ESP32-powered OLED display. This lobster bot responds to care actions through three buttons—feed, play, and sleep—each triggering unique sound effects and mood changes. The pet's emotional state decays over time, creating a dynamic interaction loop that rewards regular attention with happy expressions and audio feedback.
This guide provides a complete wiring diagram, parts list, and Arduino firmware to bring your lobster companion to life. Assembly takes about 30 minutes and requires basic soldering skills. Once uploaded, the bot displays mood states, tracks care scores, and plays cheerful tones whenever interacted with—perfect for learning ESP32 I2C communication, button handling, and simple game logic.
Wiring diagram
Gather all the parts
Assemble it in 4 steps
1. Wire the OLED face display
Connect OLED VCC to 3.3V, GND to ground, SDA to GPIO21, and SCL to GPIO22.
- Confirm the I2C address — most modules use 0x3C.
2. Add the three care buttons
Wire Feed button between GPIO32 and GND, Play button between GPIO33 and GND, and Sleep button between GPIO25 and GND. Internal pull-ups are enabled in code.
- Color-code the buttons (green=feed, blue=play, purple=sleep) for easier identification.
3. Connect buzzer and status LED
Wire piezo buzzer signal to GPIO26 (other lead to GND). Connect status LED anode to GPIO27 through a 220 Ω resistor, cathode to GND.
- The LED blinks fast when cranky, slow when sleepy, and stays solid when happy.
4. Upload and interact
Flash the sketch. ClawdBot starts happy — if you ignore it for 30 seconds it gets hungry, then bored, then cranky. Press the buttons to keep it happy and maintain the care score.
- Adjust the idle thresholds in code to make ClawdBot needier or more independent.
Review all connections
1. Connections between "clawdbot-oled-1" and "ESP32"
2. Connections between "feed-button-1" and "ESP32"
3. Connections between "play-button-1" and "ESP32"
4. Connections between "sleep-button-1" and "ESP32"
5. Connections between "clawdbot-buzzer-1" and "ESP32"
6. Connections between "clawdbot-led-1" and "ESP32"
7. Connections between "clawdbot-tamagotchi-220-ohm-resistor-1" and "ESP32"
Deploy the firmware
#include <Wire.h>
#include <Adafruit_GFX.h>
#include <Adafruit_SSD1306.h>

#define SDA_PIN 21
#define SCL_PIN 22
#define BTN_FEED 32
#define BTN_PLAY 33
#define BTN_SLEEP 25
#define BUZZER_PIN 26
#define STATUS_LED 27

Adafruit_SSD1306 display(128, 64, &Wire, -1);

enum Mood { HAPPY, HUNGRY, SLEEPY, BORED, CRANKY };
Mood mood = HAPPY;
unsigned long lastCareMs = 0;
unsigned long lastBtnMs = 0;
unsigned long lastDecayMs = 0;
int careScore = 100;

const char* moodName(Mood m) {
  switch (m) {
    case HAPPY:  return "Happy  ^_^";
    case HUNGRY: return "Hungry >_<";
    case SLEEPY: return "Sleepy -_-";
    case BORED:  return "Bored  ._.";
    case CRANKY: return "Cranky !!!";
    default:     return "Unknown";
  }
}

void playTone(int freq, int dur) {
  tone(BUZZER_PIN, freq, dur);
  delay(dur + 10);
  noTone(BUZZER_PIN);
}

void feedAction() {
  playTone(1760, 60);
  playTone(2100, 60);
  mood = HAPPY;
  careScore = min(100, careScore + 30);
  lastCareMs = millis();
}

void playAction() {
  playTone(1480, 50);
  playTone(1760, 50);
  playTone(2200, 60);
  mood = HAPPY;
  careScore = min(100, careScore + 20);
  lastCareMs = millis();
}

void sleepAction() {
  playTone(980, 90);
  playTone(780, 120);
  mood = SLEEPY;
  careScore = min(100, careScore + 15);
  lastCareMs = millis();
}

void setup() {
  Serial.begin(115200);
  delay(100);

  Wire.begin(SDA_PIN, SCL_PIN);
  display.begin(SSD1306_SWITCHCAPVCC, 0x3C);
  display.setTextSize(1);
  display.setTextColor(SSD1306_WHITE);

  pinMode(BTN_FEED, INPUT_PULLUP);
  pinMode(BTN_PLAY, INPUT_PULLUP);
  pinMode(BTN_SLEEP, INPUT_PULLUP);
  pinMode(BUZZER_PIN, OUTPUT);
  pinMode(STATUS_LED, OUTPUT);
  digitalWrite(STATUS_LED, HIGH);

  lastCareMs = millis();
  Serial.println("ClawdBot ready");
}

void loop() {
  unsigned long idleMs = millis() - lastCareMs;
  unsigned long now = millis();

  if (idleMs > 90000) {
    mood = CRANKY;
    if (now - lastDecayMs >= 1000) {
      careScore = max(0, careScore - 1);
      lastDecayMs = now;
    }
  }
  else if (idleMs > 60000) mood = BORED;
  else if (idleMs > 30000) mood = HUNGRY;

  if (now - lastBtnMs > 200) {
    if (!digitalRead(BTN_FEED))  { feedAction();  lastBtnMs = now; }
    if (!digitalRead(BTN_PLAY))  { playAction();  lastBtnMs = now; }
    if (!digitalRead(BTN_SLEEP)) { sleepAction(); lastBtnMs = now; }
  }

  display.clearDisplay();
  display.setCursor(0, 0);
  display.println("  ClawdBot Tamagochi");
  display.println("--------------------");
  display.print("Mood:  ");
  display.println(moodName(mood));
  display.printf("Care:  %d%%\n", careScore);
  display.printf("Idle:  %lus\n", idleMs / 1000);
  display.println();
  display.println("Feed / Play / Sleep");
  display.display();

  if (mood == CRANKY) {
    digitalWrite(STATUS_LED, (millis() / 180) % 2);
  } else if (mood == SLEEPY) {
    digitalWrite(STATUS_LED, (millis() / 800) % 2);
  } else {
    digitalWrite(STATUS_LED, HIGH);
  }

  delay(30);
}
Remix this project
Make it yours in one click
Open a full copy of this project in your own Schematik workspace — diagram, code, parts, and assembly steps included. Swap the sensor, add features, or redesign the whole thing with AI. The author's original stays untouched.